Springer Nature

Rehabilitation Robotics
Miglior prezzo disponibile
116,04€
Springer Nature · Spedizione gratuita
VISAPayPal
Prezzi aggiornati
Specifiche
MarcaSpringer Nature
CondizioneNuovo
Descrizione
Rehabilitation robotics is an important field of study focused on improving the gait rehabilitation of people affected by neurological disorders, ictus, cerebral palsy, and spinal cord injuries, among others. The study of rehabilitation robotics includes medical activities, kinematics dynamics, and control analysis. This book presents a complete and exhaustive analysis of the kinematics and dynamics of exoskeleton robots for rehabilitation. The forward and inverse kinematics are studied using the geometric, Denavit-Hartenberg, and screw theory approach. The dynamics analysis of exoskeleton robots using Newton-Euler, EulerâLagrange, and D'Alembert formulation are also studied. Moreover, the main control techniques for exoskeleton robots are analyzed, including robust control, impedance control, adaptive control, Lyapunov functions, and uncertainties found in dynamic systems. The book includes MATLAB applications and examples.
Storico prezzi
Ricevi una notifica se il prezzo scende
Ti invieremo un'email quando il prezzo di questo prodotto diminuirà.
- Aggiornamenti dei prezzi in tempo reale
- Oltre 50 negozi monitorati
- Avvisi gratuiti di calo prezzo
- Solo negozi verificati
Avvisami quando il prezzo scende sotto: 116,04€
Prodotti simili
Una selezione di prodotti che potrebbero interessarti. Guarda tutti
 Rehabilitation Robotics
93,08€
 Robotics And Rehabilitation Intelligence
42,79€
 Advances In Rehabilitation Robotics
295,39€
 Exoskeletons In Rehabilitation Robotics
85,59€
 Advanced Robotics For Medical Rehabilitation
85,59€
 Xxix Brazilian Congress On Biomedical Engineering - Volume 1: Biomedical Robotics, Rehabilitation, B
234,33€
 Rehabilitation
54,99€
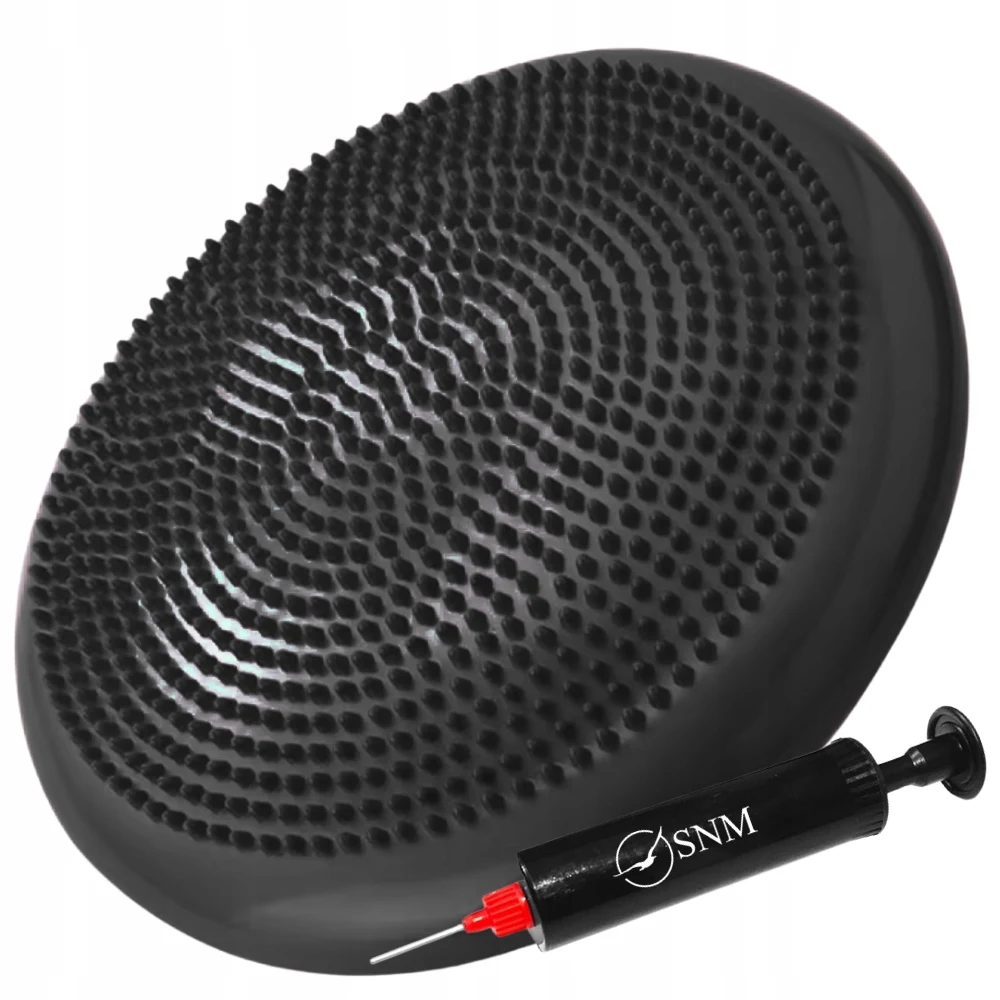 Rehabilitation Sensoriel Cush Drug Sensomotorique Pour Exerciser Rehabilitation Sensorielle
12,01€