Springer Nature
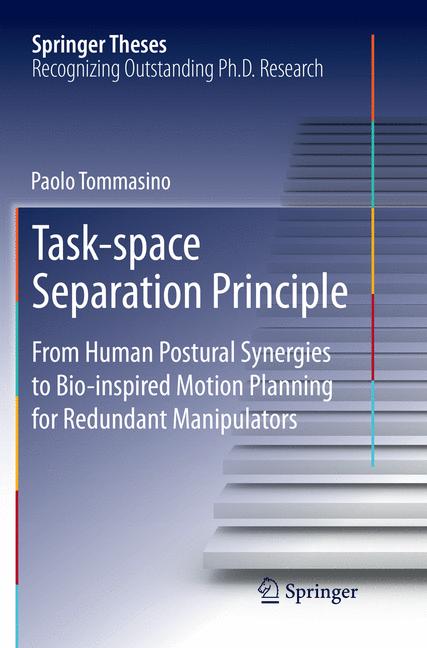
Task-Space Separation Principle
Miglior prezzo disponibile
109,99$
Springer Nature · Spedizione gratuita
VISAPayPal
Prezzi aggiornati
Specifiche
MarcaSpringer Nature
CondizioneNuovo
Descrizione
This book addresses two fundamental issues of motor control for both humans and robots: kinematic redundancy and the posture/movement problem. It blends traditional robotic constrained-optimal approaches with neuroscientific and evidence-based principles, proposing a âTask-space Separation Principle,â a novel scheme for planning both posture and movement in redundant manipulators. The proposed framework is first tested in simulation and then compared with experimental motor strategies displayed by humans during redundant pointing tasks. The book also shows how this model builds on and expands traditional formulations such as the Passive Motion Paradigm and the Equilibrium Point Theory. Lastly, breaking with the neuroscientific tradition of planar movements and linear(ized) kinematics, the theoretical formulation and experimental scenarios are set in the nonlinear space of 3D rotations which are essential for wrist motions, a somewhat neglected area despite its importance in daily tasks.
Storico prezzi
Ricevi una notifica se il prezzo scende
Ti invieremo un'email quando il prezzo di questo prodotto diminuirà.
- Aggiornamenti dei prezzi in tempo reale
- Oltre 50 negozi monitorati
- Avvisi gratuiti di calo prezzo
- Solo negozi verificati
Avvisami quando il prezzo scende sotto: 109,99$
Prodotti simili
Una selezione di prodotti che potrebbero interessarti. Guarda tutti
 Task-Space Separation Principle
84,99$
 Principle And Application Of Blind Source Separation Technology
199,99$
 Task-Space Sensory Feedback Control Of Robot Manipulators
109,99$
 The Entropy Principle
109,99$
 Mach's Principle
279,99$
 The Maximum Principle
129,99$
 The Principle Of Solidarity
139,00$
 Banach Contraction Principle
139,00$